Miguel Castillón
Miguel Castillón
Home
Projects
Publications
Experience
Projects
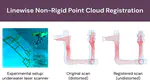
Non-rigid point cloud registration
As final contribution of my PhD thesis, I developed a non-rigid point cloud registration method that was successfully used to remove the motion distortion of 3D scans acquired with our underwater laser scanner.
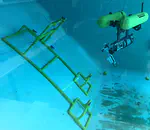
Underwater 3D scanner
One of my main contributions during the thesis has been the development of an underwater 3D laser scanner designed for autonomous mapping and manipulation.
Cite
×