Miguel Castillón
Miguel Castillón
Home
Projects
Publications
Experience
2
Linewise Non-Rigid Point Cloud Registration
During my research stay at
ASL Zurich
I developed a non-rigid point cloud registration method. You can check out the source code in
this public repository
.
Miguel Castillón
,
Pere Ridao
,
Roland Siegwart
,
César Cadena
Underwater 3D Scanner to Counteract Refraction: Calibration and Experimental Results
In this paper we present the underwater 3D laser scanner that we developed. We discuss a simplified calibration method and characterize its performance.
Miguel Castillón
,
Josep Forest
,
Pere Ridao
Extrinsic Visual-Inertial Calibration for Motion Distortion Correction of Underwater 3D Scans
Miguel Castillón
,
Roger Pi
,
Narcís Palomeras
,
Pere Ridao
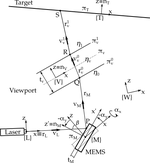
Underwater 3D Scanner Model Using a Biaxial MEMS Mirror
Miguel Castillón
,
Albert Palomer
,
Josep Forest
,
Pere Ridao
State of the Art of Underwater Active Optical 3D Scanners
Miguel Castillón
,
Albert Palomer
,
Josep Forest
,
Pere Ridao
Cite
×